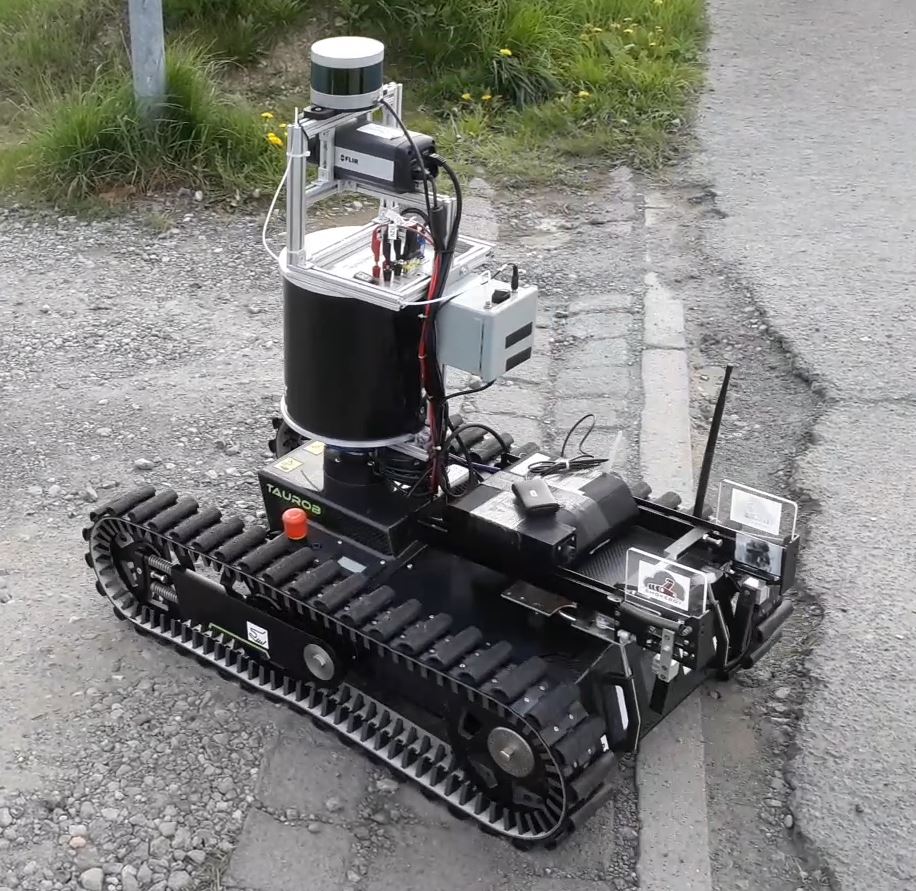
Mobile Robotics
I support you in developing intelligent mobile robotic systems that navigate and operate autonomously in dynamic environments. My expertise includes SLAM (Simultaneous Localization and Mapping), localization, and sensor fusion using technologies such as LiDAR, radar, and GNSS. I work with ROS2 (Robot Operating System 2) to build scalable and modular robotic applications.